




The MDMW457 aluminium alloy omni wheel features a 457.2mm outer diameter and a 230mm wheel width. Its wheel body is available in 6061 or 7075 aluminium alloy, with an anodized surface finish. Polyurethane rollers are arranged around the wheel circumference to support multidirectional movement in industrial material handling systems.
The wheel uses a flanged shaft connection with a keyway and a dual-bearing configuration. Its rated load capacity is specified at 8,000 kg per four-wheel set. The actual load rating should be evaluated against the wheel arrangement, operating speed, floor condition and load distribution of the complete vehicle.
For AGV, AMR and other industrial handling equipment projects, the MDMW457 can be evaluated according to the required wheel mounting dimensions, drive configuration, operating load and movement requirements. Engineering drawings and interface details should be confirmed before installation.
Technical Specifications
|
ltem |
Data |
|
Model |
MDAGV-B02 |
|
Navigation method |
Magnetic navigation |
|
Dimensions |
L880mmxW560mmxH212mm |
|
PayLoad |
200kg |
|
Moving speed |
MAX 0.9m/s |
|
Battery Data |
DC24V,30Ah,Lithium Iron Phosphate Battery |
|
Weight |
<100kg |
|
Appearance material |
Steel plate |
|
Obstacle avoidance |
Ultrasonic sensor and Bump sensor |
|
Positioning accuracy |
±5mm |
|
Control function |
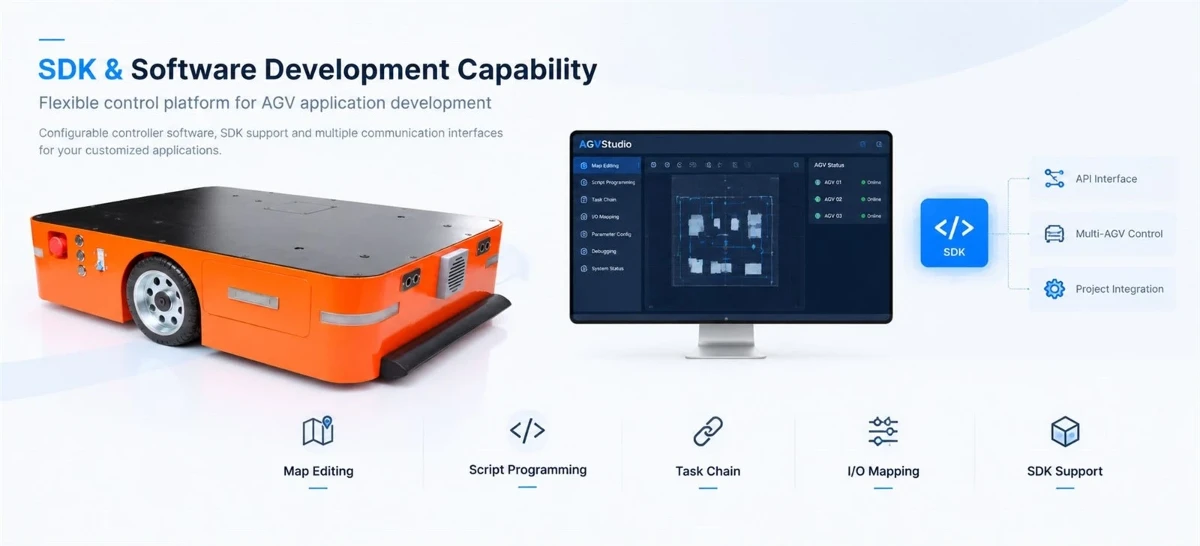
Map editing/scripting/task chain editing/various API.etc |
|
Communication |
CAN/RS232/RS485/I0/WIFI |
Wheel Structure and Component Configuration
Lorem ipsum dolor, sit amet consectetur adipisicing elit.

Aluminium Alloy Wheel Body
The wheel body is available in 6061 or 7075 aluminium alloy. An anodized surface finish is specified for the standard configuration. The selected alloy grade and surface treatment can be confirmed against the project requirements.
Polyurethane Rollers
Polyurethane rollers are distributed around the wheel circumference to provide the contact surfaces for multidirectional movement. Roller dimensions, hardness and replacement requirements should be confirmed according to the operating environment.

Bearing Assembly
The wheel uses a dual-bearing configuration. Bearing model, internal dimensions and load ratings should be included in the technical drawing or component specification.
Flanged Shaft Connection
A flanged shaft with a keyway is used for the drive connection. Flange dimensions, keyway size and shaft interface must be checked against the customer's drive assembly before production.

The MDMW457 has an outer diameter of 457.2mm and a wheel width of 230mm. Its flanged shaft and keyway connection determine the mounting interface with the drive assembly.
A dimensioned engineering drawing should be reviewed before installation or equipment integration. The drawing should identify the overall dimensions, shaft diameter, keyway dimensions, flange dimensions, mounting hole positions and bearing arrangement.
Customers integrating the wheel into an existing AGV or material handling platform can provide their current drive shaft drawing or mounting interface specifications for compatibility review.

Applications in Industrial Material Handling Systems
The MDMW457 aluminium alloy omni wheel can be evaluated for integration into industrial material handling equipment that requires multidirectional movement.
AGV Material Handling Platforms
Suitable for engineering evaluation in AGV platforms requiring forward, reverse and lateral movement. Wheel arrangement, drive control and vehicle load distribution must be matched to the platform design.
AMR Mobile Robots
Can be considered for AMR systems requiring movement in confined industrial spaces. The final configuration depends on the robot chassis, drive assembly and navigation requirements.
Heavy-Duty Industrial Transfer Equipment
The 8,000kg rated load capacity per four-wheel set provides a reference for equipment selection. Actual application suitability depends on load distribution, acceleration, operating speed, floor conditions and duty cycle.

Manufacturing and Quality Inspection
The MDMW457 production process involves wheel body machining, surface treatment, roller assembly and final dimensional inspection.
Quality checks should cover the key dimensions and interfaces required for equipment integration, including wheel diameter, overall width, flange dimensions, keyway dimensions and bearing installation.
The polyurethane rollers and bearing assemblies should also be checked against the approved component specifications. Final assembly inspection should verify component fit, rotation and visible surface condition.
Inspection records and relevant material documentation can be provided according to the project requirements.

FAQ
01.What mechanical installation conditions need to be confirmed before customizing AGV chassis?
02.What method does Three Level Protection Warehouse AGV Robot use to detect obstacles during operation?
03.What components make up the driving structure of MDAGV-B02?
04.What industrial communication interfaces does MDAGV-B02 support?
05.How to configure and debug MDAGV-B02 using AGVStudio?
06.Can MDAGV-B02 serve as the foundational platform for OEM customized mobile robots?
Certification

Office

Three Level Protection Warehouse AGV Robot
Model:MDAGV-B02


AGV and its obstacle detection and avoidance functions
Automated Guided Vehicles (AGVs) are widely used in warehouse logistics, industrial workshops, and production line material handling, and their operational safety and obstacle detection capabilities are closely related. In the actual transportation process, if AGV encounters obstacles on the driving route, it will detect the obstacle situation through corresponding sensor devices and provide necessary protective support.
During operation, AGV uses sensors to detect obstacles on the driving route and responds accordingly to avoid obstacles based on the detection situation, in order to support the safe and smooth operation of material transportation. Ultrasonic sensors and rubber touch switches together form the obstacle detection and contact protection mechanism of vehicles, which can be used to deal with obstacles encountered during operation.
Reasonable route planning, on-site layout, and sensor configuration can help improve vehicle operating conditions in warehouse passages, areas with dense shelves, and work environments where pedestrians or temporary stacking of goods may occur. By combining ultrasonic obstacle detection with rubber touch protection, AGV can provide basic safety guarantees for automated material handling and help reduce collision risks caused by obstacles during operation.
Features





AGV structure


Application

Dimension

Specification
|
ltem |
Data |
|
Model |
MDAGV-B02 |
|
Navigation method |
Magnetic navigation |
|
Dimensions |
L880mmxW560mmxH212mm |
|
PayLoad |
200kg |
|
Moving speed |
MAX 0.9m/s |
|
Battery Data |
DC24V,30Ah,Lithium Iron Phosphate Battery |
|
Weight |
<100kg |
|
Appearance material |
Steel plate |
|
Obstacle avoidance |
Ultrasonic sensor and Bump sensor |
|
Positioning accuracy |
±5mm |
|
Control function |
Map editing/scripting/task chain editing/various API.etc |
|
Communication |
CAN/RS232/RS485/I0/WIFI |
FAQ
01.What mechanical installation conditions need to be confirmed before customizing AGV chassis? 01. 定制 AGV 底盘前需要确认哪些机械安装条件?
02.What method does Three Level Protection Warehouse AGV Robot use to detect obstacles during operation?
03.What components make up the driving structure of MDAGV-B02?
04.What industrial communication interfaces does MDAGV-B02 support?
05.How to configure and debug MDAGV-B02 using AGVStudio?
06.Can MDAGV-B02 serve as the foundational platform for OEM customized mobile robots?
Certification
Office
Package

Delivery

FAQ

Hot Tags: Obstacle-Avoiding AGV, China Obstacle-Avoiding AGV manufacturers, suppliers, factory, manufacturing plant agv chassis, scalable agv chassis, process engineering agv chassis, resource allocation agv chassis, cost effectiveness agv chassis, display panel agv chassis


