


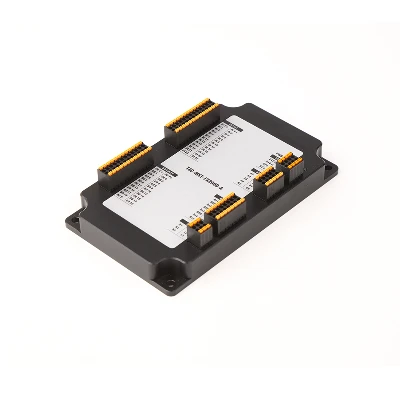


AGV Motor Controller
Model:MDSM12B60G-2ROBOT


Overview
MDSM12B60G-2ROBOT AGV Motor Controller is a dual channel low-voltage DC servo drive designed for AGV, AMR, and automatic handling equipment. It integrates two sets of independent three-phase outputs and X5 and X6 feedback interfaces inside a 185 × 85 × 33 mm body, which can simultaneously drive the left and right motors of the differential chassis, and share one 16-60 VDC input and one set of buses; Suitable for 24 V, 36 V, and 48 V platforms, it helps reduce one set of power distribution, one bus node, and one installation position.
AGV Motor Controller's Single channel rated at 12 A, peak at 26 A, overload window of 30 s, capable of covering short-term impacts such as heavy load starting, hill driving, and obstacle crossing; Using vector control combined with closed-loop PID, the low-speed torque is smooth. Supports three modes: position, speed, and torque. The factory default speed loop is set, and it is ready within 3 seconds without any faults when powered on.
Onboard CAN (CANopen CiA DS301/DS5402, supports custom CAN) and RS485 (Modbus ASCII/RTU), can be separately connected to both old and new generations of controllers; Feedback supports ABZUVW increment (TTL single ended) and Hall, with additional WD+/WD − connected to 10K NTC, allowing motor overheating protection to be determined based on the true temperature of the winding. The equipment can monitor 18 faults, and the blockage can be comprehensively judged by overload, overcurrent, and speed deviation, and reported to the upper computer through digital output.
The upper computer software Motor Control Platform 3.0 supports Type-C and RS485 debugging; When there is no computer on site, the fault number can be read by flashing the red light twice. The factory has pre-set parameters according to the matching motor, and in most scenarios, it can be tested by wiring and powering on.
feature

Dual channel controller
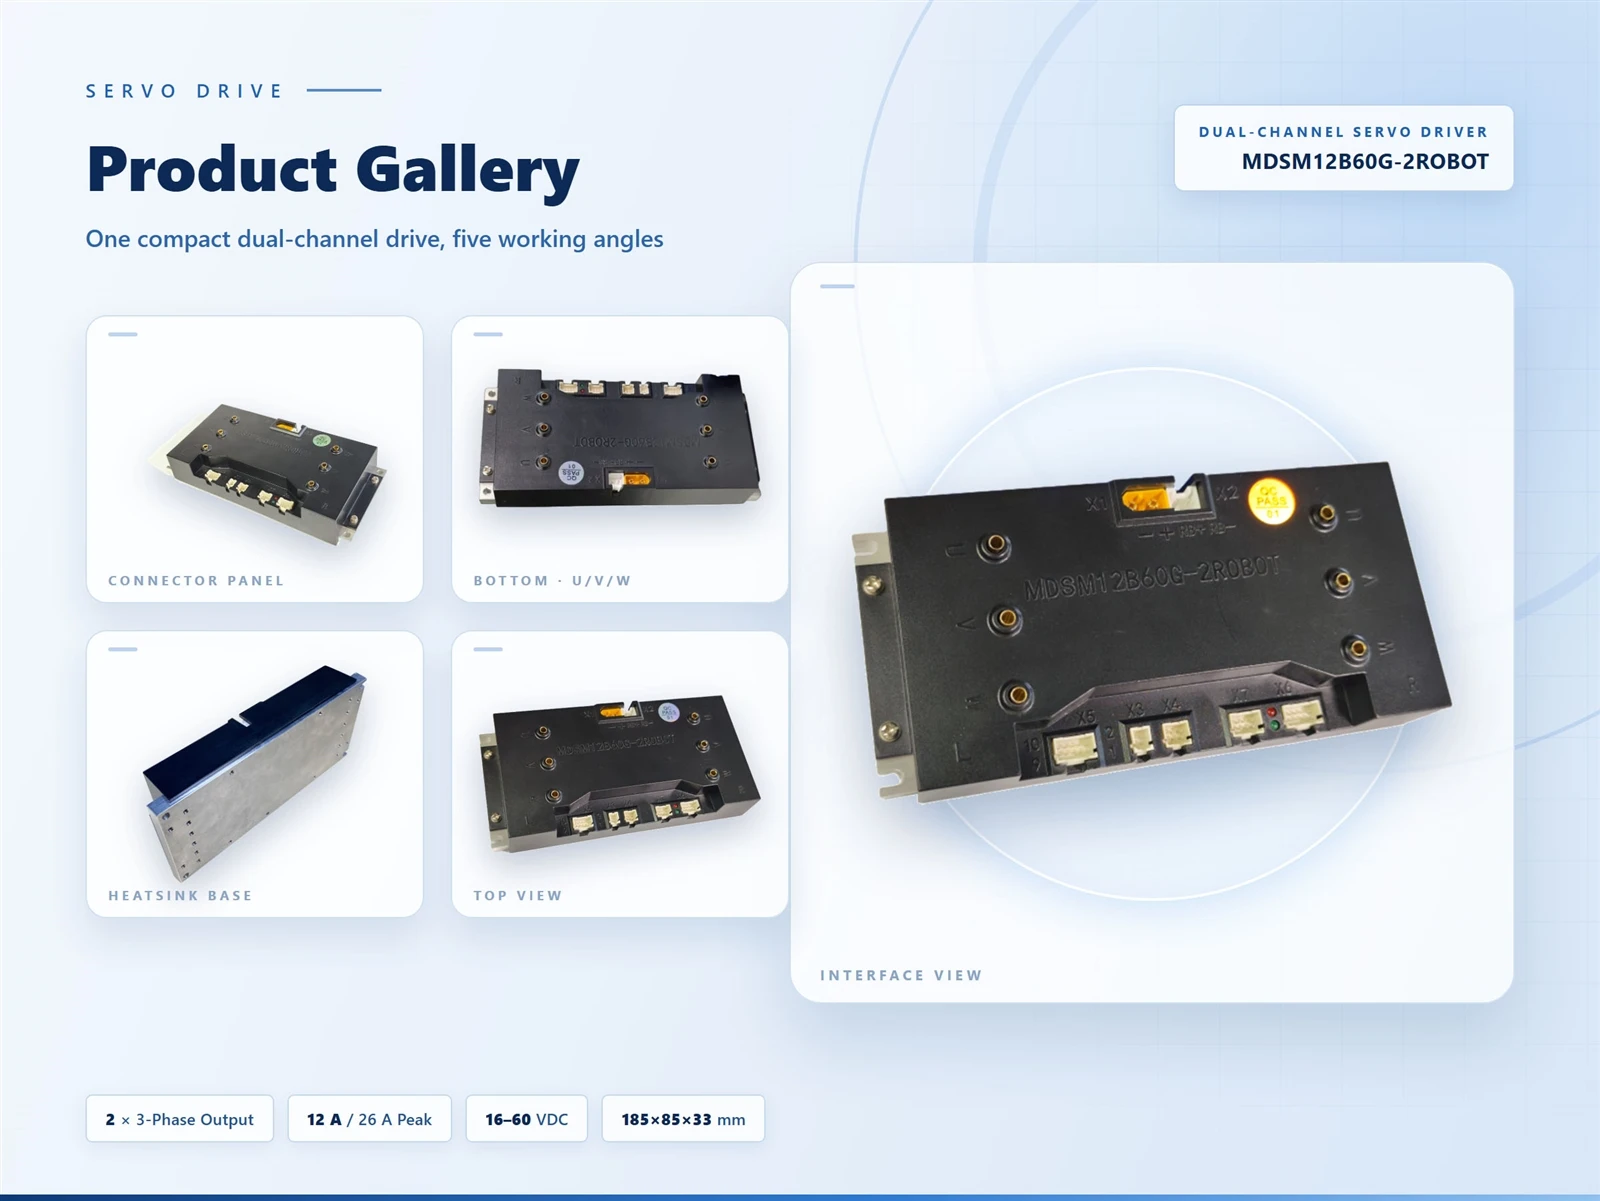
The driver integrates two independent three-phase inverter outputs, CH1/CH2, and is equipped with two motor feedback interfaces, X5/X6. The two channels share one 16-60 VDC input and one bus. For differential driven mobile platforms, this means eliminating a set of power distribution, a bus node, and an installation position; The body size is 185 × 85 × 33 mm and can be directly embedded into the chassis control cabin.
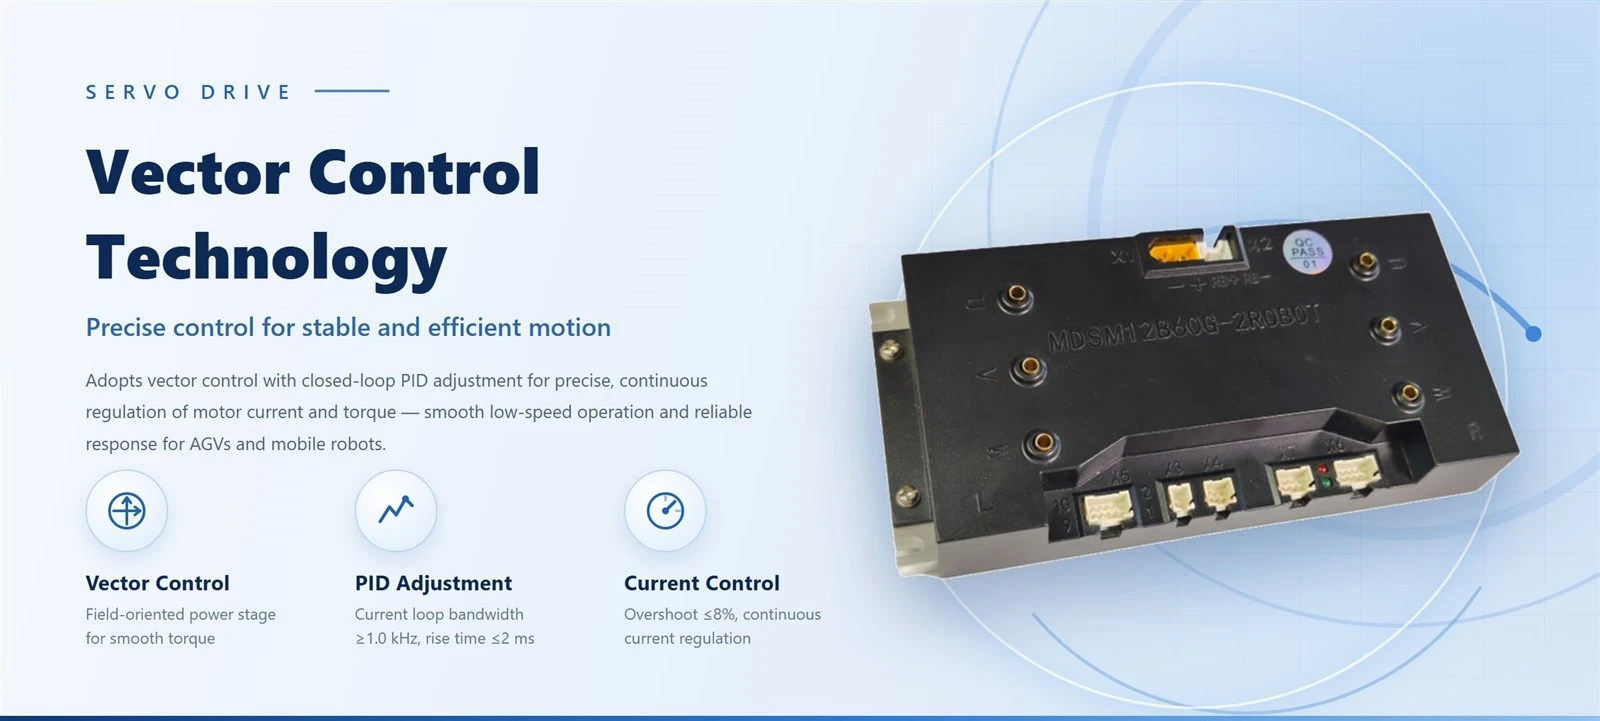
Vector control
Adopting vector control method, combined with closed-loop PID regulation to continuously correct current and torque. Current loop frequency band ≥ 1.0 kHz, step response rise time ≤ 2 ms, overshoot ≤ 8%, oscillation ≤ 2 times; The low-speed torque is smooth and the backlash is small, suitable for precise parking and low-speed cruising.

Position/speed/torque control
The position loop or torque loop can be switched according to the task, used for cruise control, fixed point parking, and constant tension output. Ready within 3 seconds without any faults when powered on. The static error rate of the speed loop is ≤ 0.4%, and the speed fluctuation is ≤ 0.1% (1000 rpm, rated torque), which is more critical for inspection and handling scenarios that require stable linear speed.

CAN and RS485
Onboard 1 CAN (CANopen CiA DS301+DSP402, also supports custom CAN protocol) and 1 RS485 (Modbus ASCII and RTU dual frame format). The old platform uses 485 and the new platform uses CANopen, and the same driver can be connected. Both channels are non isolated designs, and the CAN bus needs to be externally connected with 120 Ω terminal resistors at both ends.

ABZUVW increment+Hall+NTC temperature measurement
Support ABZUVW incremental encoder (TTL single ended) and Hall feedback for closed-loop position and commutation; Set up WD+/WD − pins to connect to a 10 K NTC thermistor, and perform motor overheating protection according to the true temperature of the winding

Multi protection level
Can monitor undervoltage, overvoltage, overcurrent, overload, phase loss IGBT,EEPROM, There are a total of 18 abnormalities, including overheating of the drive, motor, current deviation, speed deviation, encoder error, Hall error, communication timeout, runaway, open circuit of the brake, abnormal position, and version error. Blocked rotor is determined through a comprehensive analysis of overload, overcurrent, and speed deviation, and can be directly reported to the upper computer through digital output without the need for an external current relay.
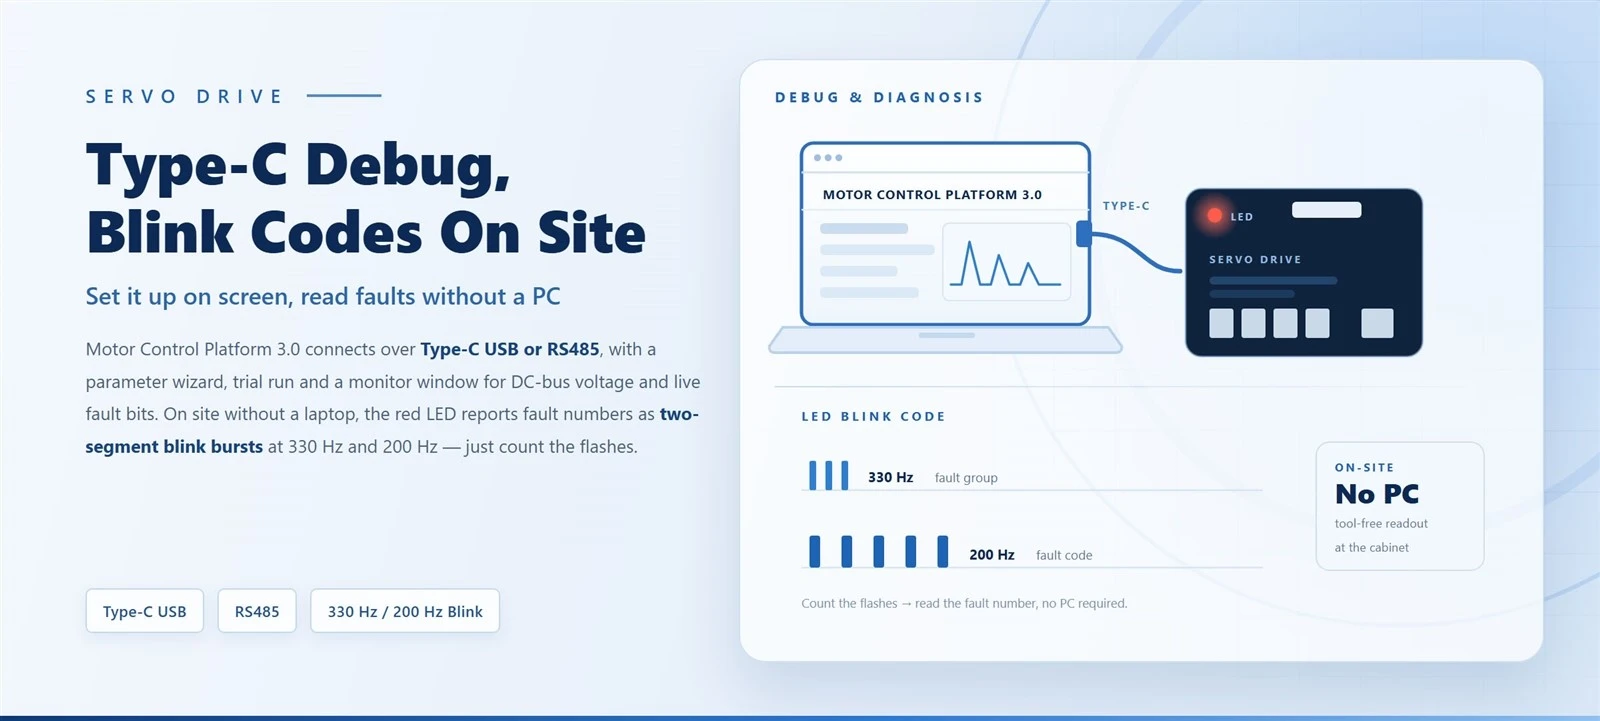
Type-C direct connection debugging+LED flashing code reading fault
Supports two connection methods, Type-C USB and RS485, including parameter wizard, trial operation, and monitor window (bus voltage, real-time fault position). When there is no computer on site, the red indicator light flashes twice at 330 Hz/200 Hz to report the fault number, and maintenance personnel can locate it by flashing it several times. The factory has pre-set parameters according to the matching motor, and in most cases, it can be tested by powering on.
Product detail
Dimension

Specification
|
ltem |
Parameters |
|
Model |
MDSM12B60G-2ROBOT |
|
Limit Power Supply Range |
16~60VDC |
|
Rated Current |
12Arms±2% |
|
Maximum Current |
26Arms±1% |
|
Maximum Overload Time |
30S |
|
Overload Recovery Time |
90S |
|
Rated insulation withstand voltage |
Input and output DC 1000V leakage current to the enclosure less than 3mA. |
|
Drive Frequency |
16KHz±0.1KHz |
|
Insulation resistance of the whole machine |
≥1M at 40°temperature and 95%humidity |
|
Power Control Method |
Vector control |
|
Mean time between failures(MTBF) |
≥5000 hours |
FAQ
01.How to use 30 second overload? Do we need to add extra heat dissipation for continuous full load?
02.How are the two channels divided in hardware?
03.Can CANopen and Modbus be used simultaneously? What would happen if communication was lost?
04.The encoder is TTL single ended, can it be directly connected to a differential encoder?
05.What will happen if NTC temperature measurement is not connected? How to connect a 10K thermistor?
06.After the new machine is installed and powered on, if the motor does not turn after enabling it, in what order should it be checked?


Hot Tags: AGV motor controller, China AGV motor controller manufacturers, suppliers, factory, servo motor driver for wind turbines, servo motor driver for cutting machines, servo motor driver for value added product, servo motor driver for din deutsches institut f r normung standards, servo motor driver for logistics applications, servo motor driver for drones


