


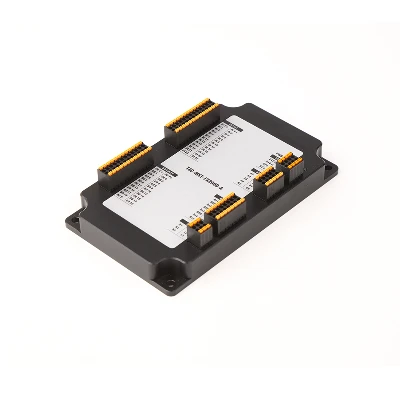


BLDC Driver Electrical Controller
Model:MDSM25B60G-ROBOT


Overview
BLDC Driver Electrical Controller, based on vector control (FOC) and closed-loop PID tuning, manages the operation status of the motor. Supports forward rotation, reverse rotation, reversing, and braking, and can directly drive the AGV chassis and robot actuators. 6 A/12 A/25 A three current levels, 16-60 VDC wide voltage input, compatible with 24 V and 48 V battery platforms; RS485 and CAN dual bus, convenient for connecting to the vehicle controller or PLC.
Core Features
1 | Vector control and commutation management
Adopting magnetic field oriented (vector) control, coupled with closed-loop PID real-time tuning, to handle every forward rotation, reverse rotation, commutation, and braking smoothly. Combined with the release interface (external brake resistor) and the brake output, it can achieve fast parking and power-off maintenance.
2 | Real time current regulation and overcurrent protection
The output current is sampled in real-time and continuously corrected, and overcurrent protection will intervene before the power stage or winding is damaged. The rise time of the current loop step response is ≤ 2 ms, overshoot is ≤ 8%, and frequency band is ≥ 1.0 kHz, suitable for working conditions with frequent load changes. In situations with large load fluctuations, selecting the correct rated level and setting the limit values are equally crucial as the hardware itself.
3 | Position/speed/torque three ring optional
The factory default speed loop can switch between position loop or torque loop according to the task, used for cruise control, fixed point parking, or constant force output. Enter the ready state within 3 seconds without any faults when powered on.
4 | Three types of feedback interfaces, compatible with mainstream encoders
Differential ABZUVW incremental (configurable as TTL or Hall), serial absolute encoder. When wiring, it is necessary to confirm that the encoder type matches the model, and that the pin definitions are consistent with the manual.
5 | Design for AGV and automatic handling equipment
Located between the dispatch layer and the wheels, it converts the instructions issued by the vehicle controller into rotation; After setting the speed, heading, and travel limits, both traction and steering can be undertaken. The final accuracy, response, and smoothness also depend on the mechanical structure, selected motor, and navigation scheme.
6 | Full dimensional fault monitoring, fast positioning
It can monitor more than ten abnormalities such as bus undervoltage/overvoltage, overcurrent, overload, board overheating, motor overheating, phase loss, current/speed deviation, encoder failure, communication timeout, etc; The LED is encoded and reported based on the number of flashes, and the PC debugging software (Motor Control Platform 3.0) can expand the complete register view to shorten the troubleshooting path.
7 | Three current specifications, selected according to peak value
Rated at 6 A/12 A/25 A, peak at 12 A/24 A/50 A. The selection should be based on peak demand and actual duty cycle, rather than just continuous values - the overload window that determines the specification varies randomly (6-30 s).
8 | Dual bus+digital IO, easy to integrate
RS485 (Modbus ASCII/RTU) and CAN (CANopen CiA 301/402+custom protocol); 4-channel digital input, 2-channel open collector output; Onboard 5-digit control mode code and 2-digit terminal resistor dialing, tool free on-site setting.
feature


Product detail

Dimension

Specification
|
ltem |
Parameters |
|
Model |
MDSM25B60G-ROBOT |
|
Limit Power Supply Range |
16~60VDC |
|
Rated Current |
25Arms±2% |
|
Maximum Current |
100Arms±1% |
|
Maximum Overload Time |
6S |
|
Overload Recovery Time |
90S |
|
Rated insulation withstand voltage |
Input and output DC 1000V leakage current to the enclosure less than 3mA. |
|
Drive Frequency |
6~16KHz±0.1KHz |
|
Insulation resistance of the whole machine |
≥1M at 40°temperature and 95%humidity |
|
Power Control Method |
Vector control |
|
Mean time between failures(MTBF) |
≥5000 hours |
FAQ
01.What motor parameters are required when purchasing MDSM series servo drives?
02.Can MDSM series servo drives be used for robot equipment that requires precise positioning?
03.Why is the heat dissipation design of MDSM series servo drives important?
04.Can MDSM series servo drives of different models be directly interchangeable?
05.How can MDSM series servo drives adapt to different automation control schemes?
06.What motor control applications are suitable for MDSM series servo drives?


Hot Tags: BLDC Driver Controller, China BLDC Driver Controller manufacturers, suppliers, factory, servo motor driver for high quality product, servo motor driver for cnc machines, servo motor driver for industrial applications, servo motor driver for iec international electrotechnical commission standards, servo motor driver for drilling machines, servo motor driver for regulators


