


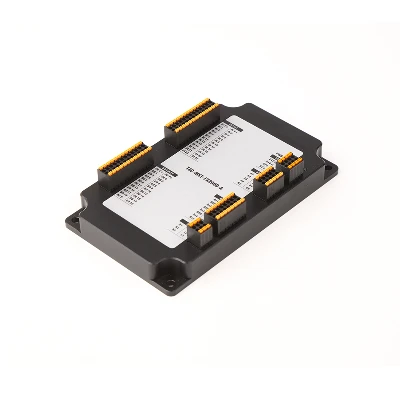


BLDC Servo Electronic Driver Controller
Model:MDSM25B60G-ROBOT


Overview
The BLDC Servo Electronic Driver Controller supports motor parameter matching, drive configuration, debugging, and operation monitoring through the accompanying Motor Control Platform 3.0 software, making it convenient for engineers to complete system settings according to actual equipment needs. The BLDC Servo Electronic Driver Controller provides RS485 and CAN communication interfaces, which can be used for communication with compatible control systems. The specific protocol support needs to be confirmed according to the model and configuration; Some models also support pulse direction control, making it easy to receive external motion control commands. By reasonably configuring motor parameters, control commands, and communication methods,BLDC Servo Electronic Driver Controller can be applied to robots, mobile devices, and industrial automation systems, helping equipment manufacturers meet different motion control and integration needs.
feature

Vector Control Technology
The BLDC Servo Electronic Driver Controller adopts vector control technology, combined with PID regulation and real-time current detection, to achieve precise control of motor forward and reverse rotation, commutation, braking, speed and position. Supports RS485 (Modbus ASCII/RTU) and CAN communication (CANopen and custom CAN protocol), suitable for motor drive and control of mobile robots, service robots, exoskeleton robots, and industrial automation equipment.

Position, speed, and torque control modes
The BLDC Servo Electronic Driver Controller supports position loop, speed loop, and torque loop control modes. The factory default adopts speed loop control, and the corresponding mode can be selected according to the motion control requirements of the equipment. Combining vector control technology with PID regulation to achieve flexible control of motor position, speed, and torque, suitable for mobile robots, service robots, and industrial automation equipment.

CAN and RS485 communication
The BLDC Servo Electronic Driver Controller supports RS485 and CAN communication. RS485 is compatible with Modbus ASCII and RTU protocols, and the CAN interface supports CANopen (CiA 301, CiA 402) and custom CAN protocols, making it easy to communicate and integrate with robot control systems and automation equipment. The specific communication interface and protocol configuration should be based on the corresponding model.

Hall sensor and encoder feedback
BLDC Servo Electronic Driver Controllers support Hall feedback and encoder feedback, can adapt to incremental encoder ABZUVW differential signals, and support TTL level adjustment and serial absolute value encoder. The specific feedback method depends on the driver model, which is convenient to meet the feedback and motion control needs of different motors.

I/O input/output and pulse direction control
The BLDC Servo Electronic Driver Controller supports digital input/output (I/O) and pulse and direction signal control, which can be used for motor enable, limit, origin and other related controls, and motion control is achieved through pulse commands. The I/O configuration and pulse interface parameters of different models vary, and the interface definition of the corresponding model needs to be confirmed when selecting.

Monitoring of overcurrent, overvoltage, and overheating faults
BLDC Servo Electronic Driver Controller have various fault monitoring functions, which can identify motor overcurrent, overload, driver overheating, motor overheating, power overvoltage and undervoltage and other abnormalities. Relevant fault information is displayed through status indicator lights and upper computer monitoring windows to help users timely troubleshoot equipment operation abnormalities. The specific functions are subject to the corresponding model configuration.

PC upper computer debugging and status monitoring
BLDC Servo Electronic Driver Controller support PC upper computer debugging, and can be matched with motor parameters, tested, and monitored for operation status through Motor Control Platform 3.0 software, helping users complete drive debugging and view relevant fault information. When matching motor parameters for the first time, it is necessary to ensure that the motor is in an unloaded state.
Product detail

Dimension

Specification
|
ltem |
Parameters |
|
Model |
MDSM25B60G-ROBOT |
|
Limit Power Supply Range |
16~60VDC |
|
Rated Current |
25Arms±2% |
|
Maximum Current |
100Arms±1% |
|
Maximum Overload Time |
6S |
|
Overload Recovery Time |
90S |
|
Rated insulation withstand voltage |
Input and output DC 1000V leakage current to the enclosure less than 3mA. |
|
Drive Frequency |
6~16KHz±0.1KHz |
|
Insulation resistance of the whole machine |
≥1M at 40°temperature and 95%humidity |
|
Power Control Method |
Vector control |
|
Mean time between failures(MTBF) |
≥5000 hours |
FAQ
01.What devices are BLDC Servo Electronic Driver Controller suitable for?
02.What control methods does the BLDC Servo Electronic Driver Controller support?
03.How to configure and debug BLDC Servo Electronic Driver Controllers?
04.Does the BLDC Servo Electronic Driver Controller support RS485 and CAN communication?
05.What are the fault protection functions of MDSM series servo drives?
06.How to troubleshoot BLDC Servo Electronic Driver Controller when they malfunction?


Hot Tags: BLDC Electronic Driver Controller, China BLDC Electronic Driver Controller manufacturers, suppliers, factory, servo motor driver for generators, servo motor driver for ce conformit europ enne certification, servo motor driver for textile machinery, servo motor driver for gb guobiao chinese national standards standards, servo motor driver for safety features, servo motor driver for smooth operation


