Intelligent Hoisting AGV

Intelligent Hoisting AGV

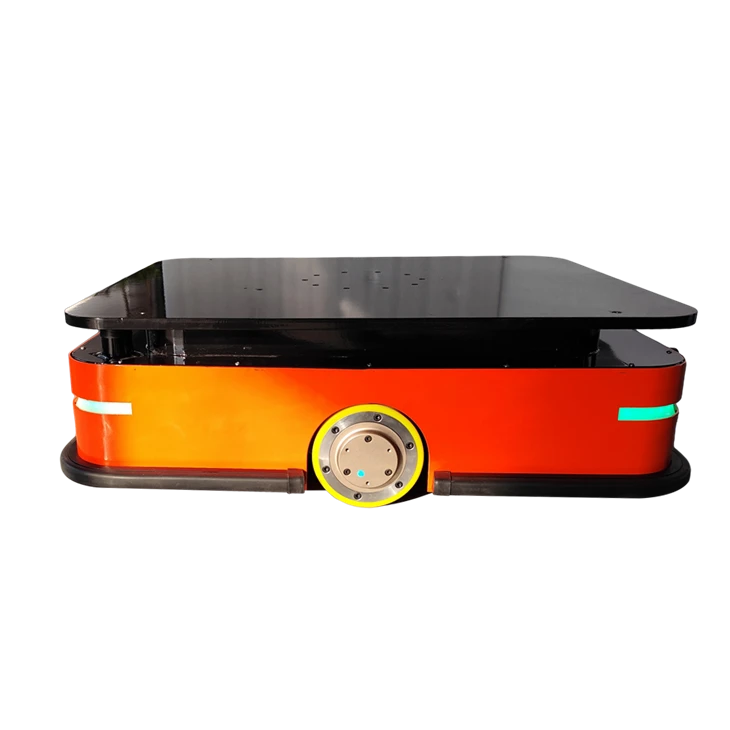
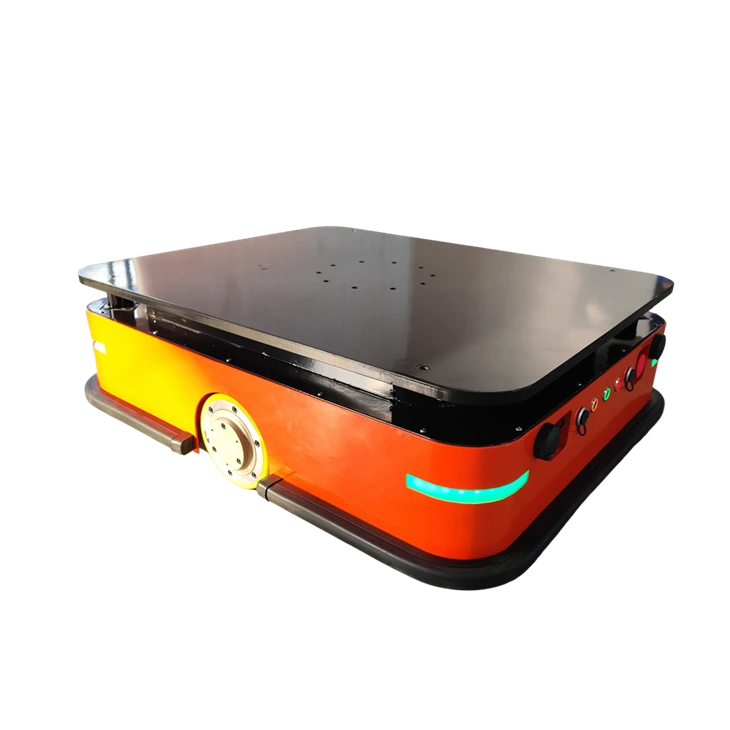
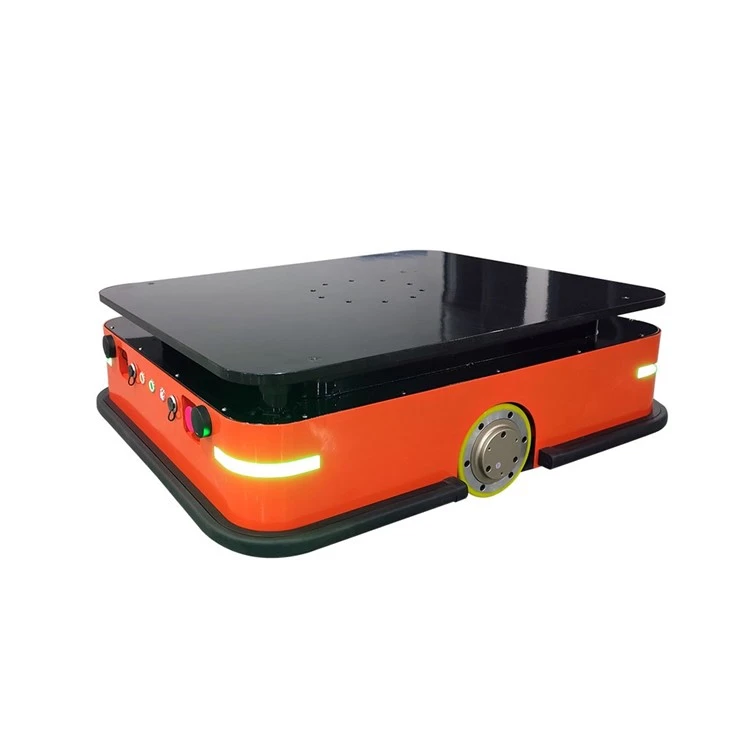
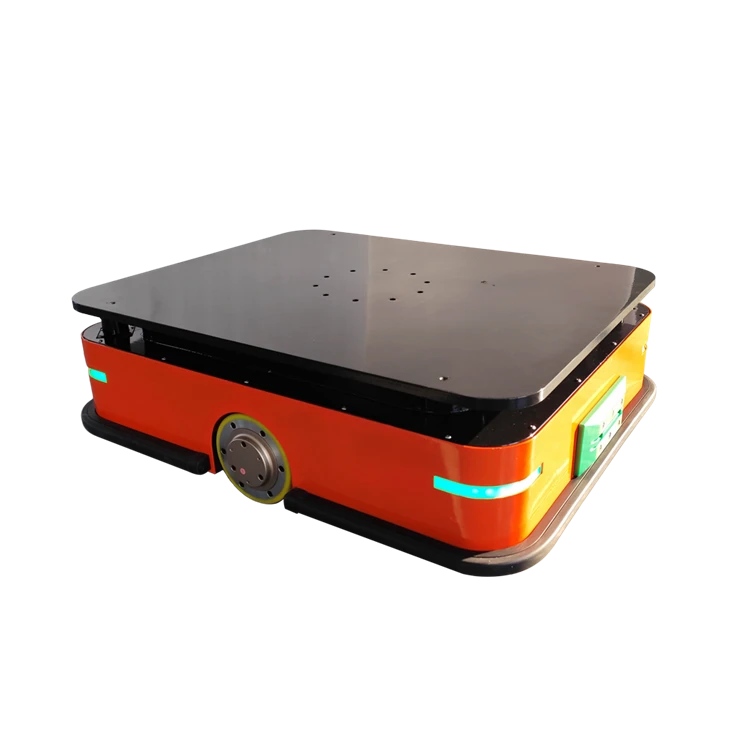
Autonomous Movement Intelligent Jacking AMR Robot combine automatic guidance technology and lifting mechanisms to travel autonomously on a preset path and lift materials to a specified height as needed. Its core components include agv lift vehicle body, drive unit, navigation system, control system, lifting mechanism and safety protection system.
Send Inquiry
Chat Now

Autonomous Movement Intelligent Jacking AMR Robot
Model:MDAMR-SL600

product-1172-359

product-1172-456


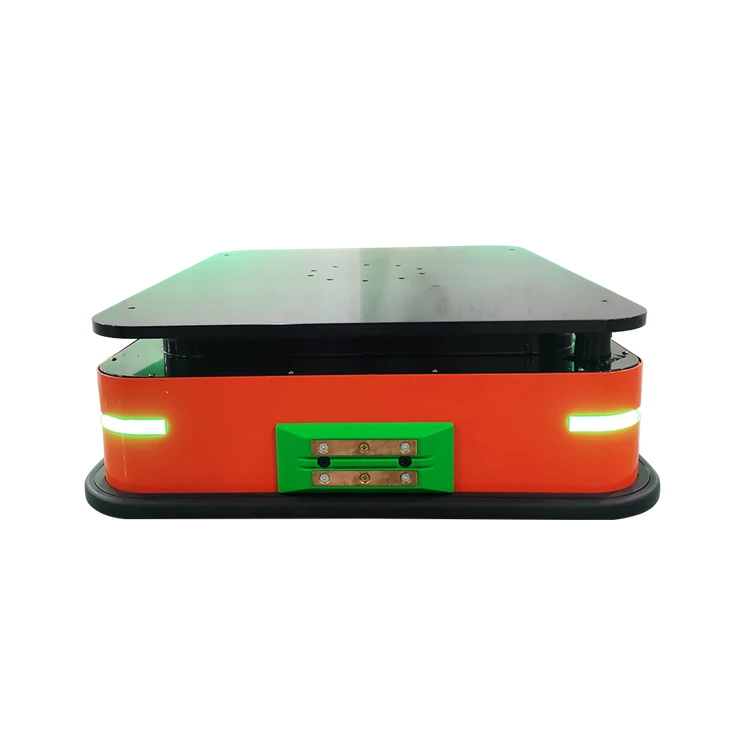
The Autonomous Movement Intelligent Jacking AMR Robot is designed for lifting and transportation tasks up to 600kg. The Autonomous Movement Intelligent Jacking AMR Robot size is 950 × 780 × 285mm, with a top lifting platform with a rated load of 600kg and a lifting stroke of 50mm. It can lift shelves, material trucks, and goods off the ground for transportation, and can also directly transport cardboard boxes, turnover boxes, and fixtures on a flat plate. The navigation adopts laser SLAM, which continuously scans the environment and updates the map in real time while driving, corrects its own position, slows down and detours according to obstacles ahead, runs at a speed of 800mm/s under rated load, and has a repeat positioning accuracy of ± 10mm when stopping. The lifting action is controlled by the vehicle button or dispatch command, and the lifting and lowering are smooth. The goods will not shift due to emergency lifting and stopping during transportation. It is suitable for the fixed-point transportation of finished materials, fixtures, and material trucks in scenarios such as automotive parts, mechanical processing, packaging, and electronic assembly. It hands over repetitive transportation to equipment, reducing manual pushing and forklift interference. At the same time, it uses laser obstacle avoidance, mechanical anti-collision strips, and emergency stops on both sides of the vehicle to reduce the risk of human-machine collision. Lithium iron phosphate batteries provide 6-8 hours of battery life, 2 hours of full charge, low battery automatic recharge, and can support multiple shifts of continuous operation. For workshops that frequently transport materials back and forth, it undertakes a stable and predictable transportation capacity, rather than just a transportation tool.


Specification


ltem

Data

Model

MDAMR-SL600

Navigation method

SLAM

Dimensions

L926*W756*H285mm

Lifting Height

60mm

Drive Type

Differential drive

Walking Direction

Forward and reverse/left and right tur/ rotate in place

Maximum Speed

1.5m/s

Rated Load

600kg

Charging MethodBattery

Lithium iron phosphate battery

Positioning accuracy

Manual/automatic charging

Safety Protection

LIDAR+Collision Bumper+Emergency Stop Button

Communication

Wireless


Products Description


1laser navigation


1 Laser Navigation for Flexible Industrial AMR Deployment


2 600kg


2 600kg heavy load and 50mm lifting capacity


3 long endurance


3 Automatic charging supporting 24-hour continuous operation


4 deployment


4 From laser SLAM mapping to autonomous operation


Dimension


structure


structure


6 structure


5 Laser Navigation Automatic Charging


more Specification


7 parameters


6 parameters description


Product detail

 
product-280-287
product-281-287
product-281-287
 
product-280-287
 

FAQ


01.What preparations need to be made on site before drawing?

It is recommended to scan during the time period with the least personnel in the area and remove frequently moving objects such as material trucks and pallets in advance; For surfaces such as glass, mirrors, and metal columns that reflect or transmit light and affect radar scanning, materials that do not affect scanning can be temporarily affixed at the scanning plane height. When creating a map, use a computer to directly connect to the device hotspot or network cable to avoid incomplete maps caused by disconnection halfway.

02.How to operate the power on/off? How to determine if the startup has been successful?

The power switch is located on the chassis of the vehicle. When the button is pressed, the light will turn on and a voice prompt will be issued, indicating successful startup; Press and hold the button again to turn off the device. It is recommended to shut down the battery when it is not used for a long time or stopped during holidays. If it is not used for more than a month, it should be regularly charged and maintained to avoid battery depletion.

03.What do the car's light strips and voice prompts represent respectively?

The light strip is used to display the operating status of the device. Normal driving, standby, alarm and other states can be distinguished by changes in the light; The startup voice is used to confirm the completion of startup, and is accompanied by sound and light alarm prompts in case of abnormalities. The specific correspondence between light color and status is based on the settings during on-site debugging, and the scheduling interface will also display the current status of the vehicle synchronously.

04.Which components are considered vulnerable parts and need to be kept on hand for long-term operation?

According to the manual inspection items, the driving wheel and driven wheel (wear, foreign object entanglement), LED light strip (not lit or inconsistent color), laser radar lens (dust accumulation affects scanning), charging brush plate and charging pile electrode (stains affect contact), and anti-collision strip are components that need to be checked regularly. It is recommended to keep drive wheels, light strips, and charging brushes on hand according to the fleet size to shorten downtime caused by malfunctions.

05.When the Autonomous Movement Intelligent Jacking AMR Robot is first launched, how to arrange the debugging sequence in a more secure manner?

It is recommended to proceed in the order of "confirming vehicle online → exiting navigation mode → remote mapping → naming, saving and exporting map → importing scheduling project → configuring communication, point and path → no-load test run → load verification". During the no-load phase, first run the entire route and key points such as entrances and intersections, and then gradually load the actual load, exposing the problem earlier.

06.How to grasp the vehicle's position and task execution status in daily operation?

On the scheduling interface, the Autonomous Movement Intelligent Jacking AMR Robot's position on the map, current tasks, and operational status can be viewed in real-time; After expanding the vehicle properties, remote operations such as power on/off, obstacle avoidance, and jacking can also be performed. The status light strip and sound and light alarm on the equipment side serve as on-site supplementary prompts, making it easy to directly determine whether the vehicle is normal next to the channel.


product-1159-760

product-1159-1007

product-1159-519


product-1159-735product-1159-741

product-1159-722

Hot Tags: Intelligent Hoisting AGV, China Intelligent Hoisting AGV manufacturers, suppliers, factory, gps guided lifting agv, lifting agv for equipment movement in logistics centers, tool transfer lifting agv, user friendly lifting agv, self navigating lifting agv, lifting agv for logistics handling in logistics centers